Task demonstrations
Show how people perform a task from start to finish, including the tools and objects they use. We agree on which variations and exceptions to collect.
We collect data on how people do real work, then turn it into structured datasets for robot training and evaluation. Together we define the tasks, the annotations, and how to review the data before delivery.
Discuss a data collaboration
Real tasks and their variations
Task coverage, quality, and privacy
Actions, objects, tools, and outcomes
Datasets and quality records
Show how people perform a task from start to finish, including the tools and objects they use. We agree on which variations and exceptions to collect.
Label when each action happens, what it involves, and whether the person completes it, retries it, or runs into a problem.
When the project calls for it, estimate hand landmarks and object regions over time. Review visibility and limitations in the estimates.
Check coverage, visibility, and label accuracy against the agreed criteria. We track what we collect, what passes review, and what we can deliver.
Each label points to a specific moment in the task demonstration. The diagram shows how a dataset can link actions, hand motion, and review notes.
A real task, start to finish
Pick / align / assemble / check
Left and right hand landmarks and estimate status
Quality, gaps, and approved uses
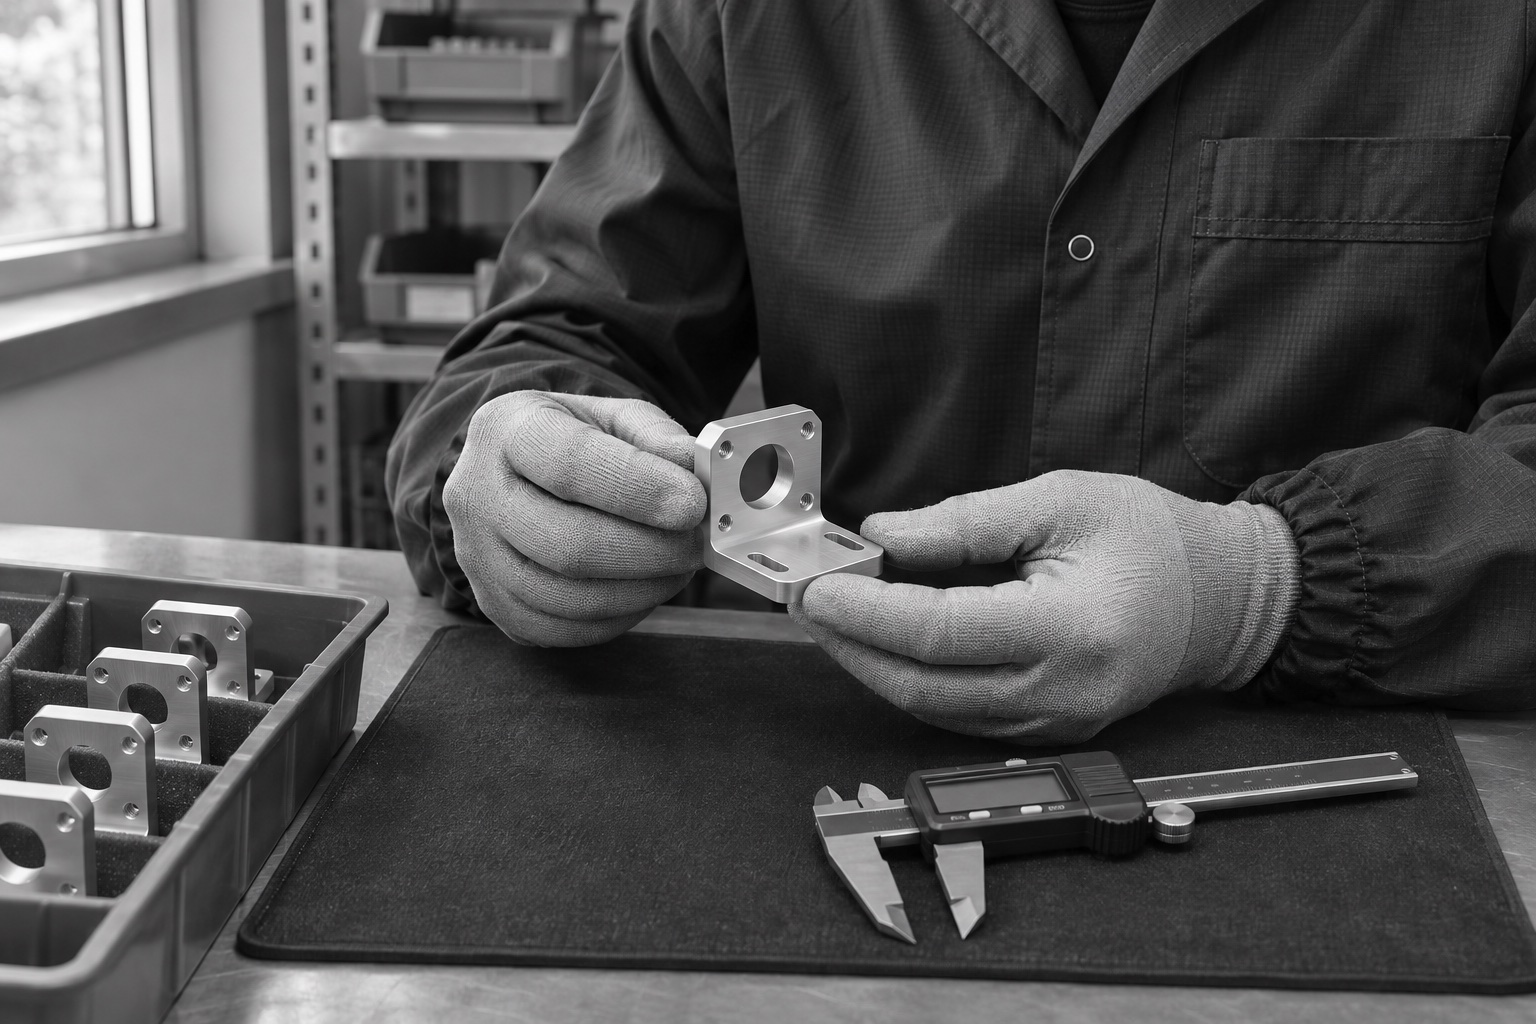
We start with tasks such as assembly, packaging, or inspection. Together we choose which steps, variations, and exceptions to document and how to collect the data within the site’s normal workflow.
Check protective equipment, hygiene requirements, and mounting comfort. Stop recording if safety issues arise.
Confirm participation and review personal or confidential information. Footage is not used for individual performance assessment.
Share material the site reviewed and approved within the agreed purpose and scope.
Choose the tasks and variations that matter to your training or evaluation goals.
Check whether it covers the relevant actions and exceptions. Agree on annotations and acceptance criteria.
Scale collection to the agreed scope and check the dataset against the delivery requirements.
Tell us which tasks matter, what the data needs to describe, and how you plan to use it.
Discuss a data collaboration